Robots & Projects

Our robots

A season-by-season record of what Team 2609 has designed and built, pulled from our own tech binders where we have them, and a short summary everywhere else.

  • Spin Cycle, a Team 2609 competition robotSpin Cycle
    2026REBUILTFeatured robot

    Spin Cycle

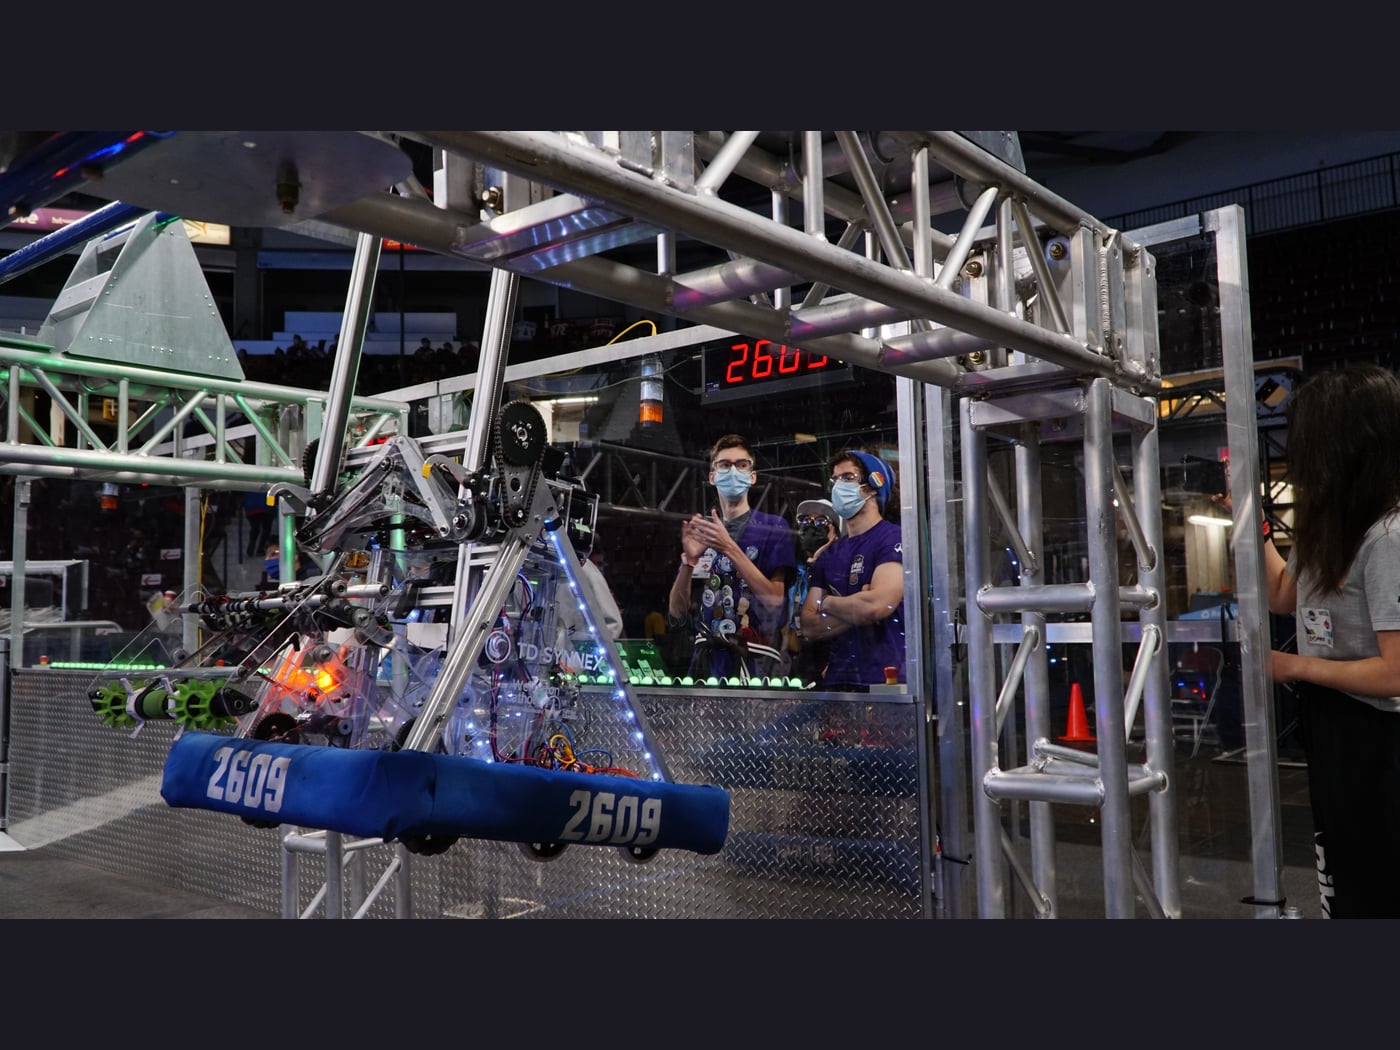
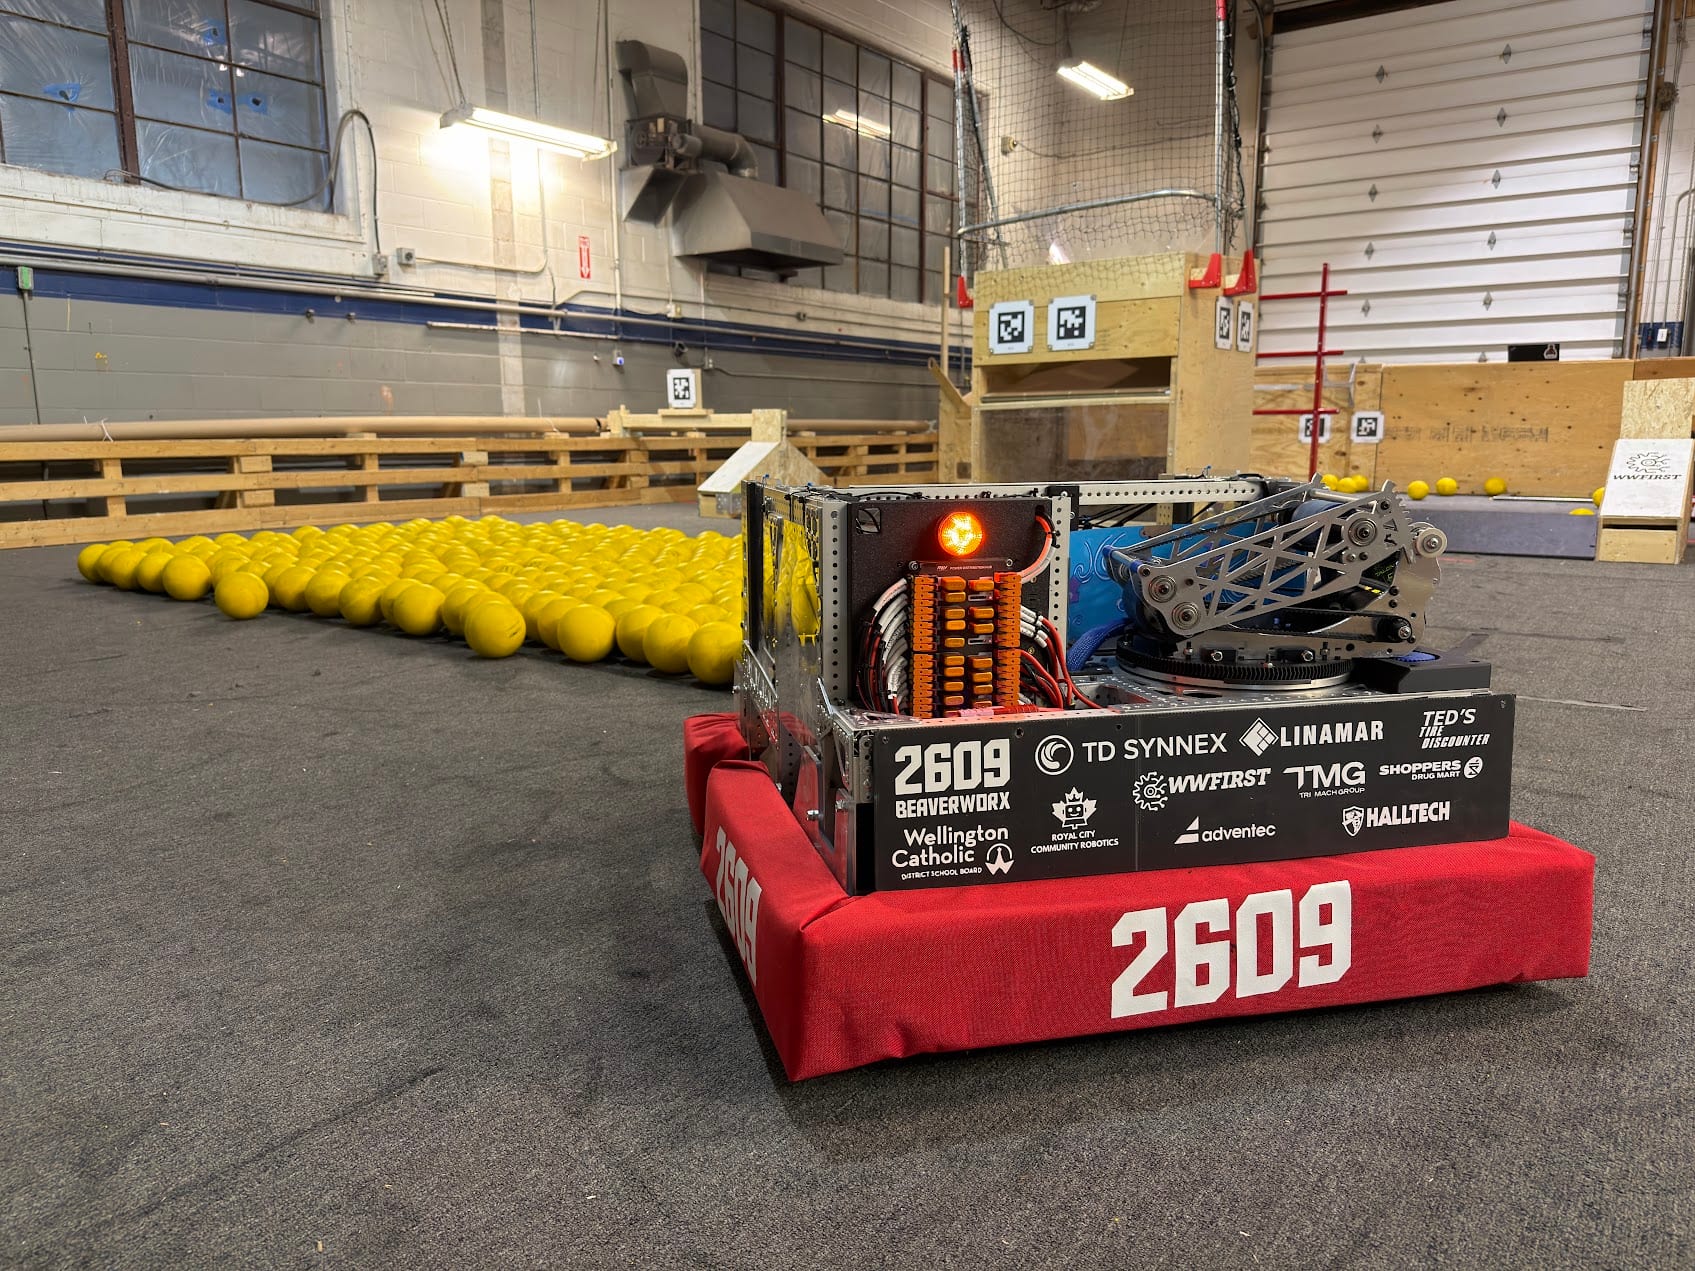
    Spin Cycle is Team 2609's 2026 competition robot, built for REBUILT. A swerve drivetrain and a turret-mounted double-wheel shooter collect, index, and fire Fuel.

    • Innovation in Control Award sponsored by nVent, ONT District North Bay & University of Waterloo Events
    • North Bay: 4th of 25 (Alliance Captain) · Waterloo: 11th of 31 · Provincials: 38th of 49
    Drivetrain
    Swerve, custom SDS Mk4n / Mk4i modules, L2+ gearing (~18 ft/s)
    Key mechanisms
    Compliant-wheel intake, rotating indexer, and vertical feeder
    Turret & shooter
    Double-wheel turret shooter driven by dual Kraken X60 motors
    Watch this Robot in Action!(opens in a new tab)Final score 508–380 in Semifinal 6, FIRST Ontario Provincial Championship
  • Nautilus, a Team 2609 competition robotNautilus
    2025REEFSCAPE

    Nautilus

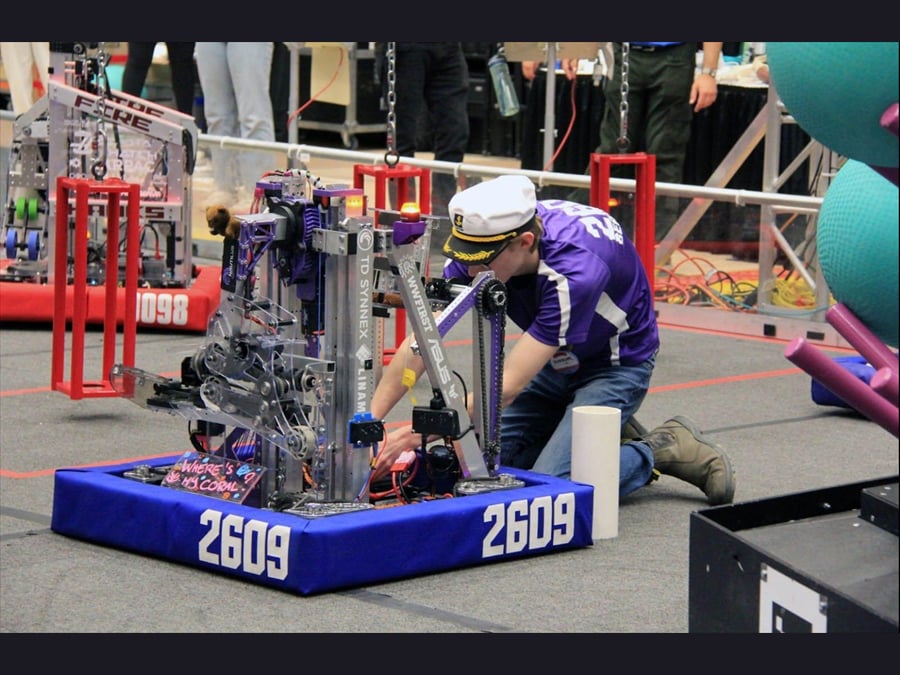
    Nautilus was Team 2609's 2025 competition robot, built for REEFSCAPE. A ground intake fed a cascade-rigged elevator and rotating arm, ending in a dual-purpose gripper that could score both Coral and Algae. Its climber, inspired by Team 2582 PantherBots, grabbed the Cage and flipped the robot upside down to lift it off the ground.

    • Team Sustainability Award sponsored by Dow, ONT District Niagara College Event
    • Competed at STEMley Cup Championship, the Provincial Championship (Technology Division), and the Waterloo District Event
    Drivetrain
    Swerve, SDS Mk4n modules, L2+ gearing (~18 ft/s), Kraken X60 drive/steer
    Key mechanisms
    Ground intake, cascade elevator (66.5" max height), 2-jointed arm, coral/algae gripper
    Climber
    Kraken-driven Cage climb, 648:1 reduction, inspired by Team 2582 PantherBots
    Vision & software
    Java, Command-based; dual Limelight 3+ (pose estimation + Coral detection); PathPlanner autonomous
    Watch this Robot in Action!(opens in a new tab)Final score 199–126 in Qualification 54, FIRST Ontario Provincial Championship
  • Apollo, a Team 2609 competition robotApollo
    2024CRESCENDO

    Apollo

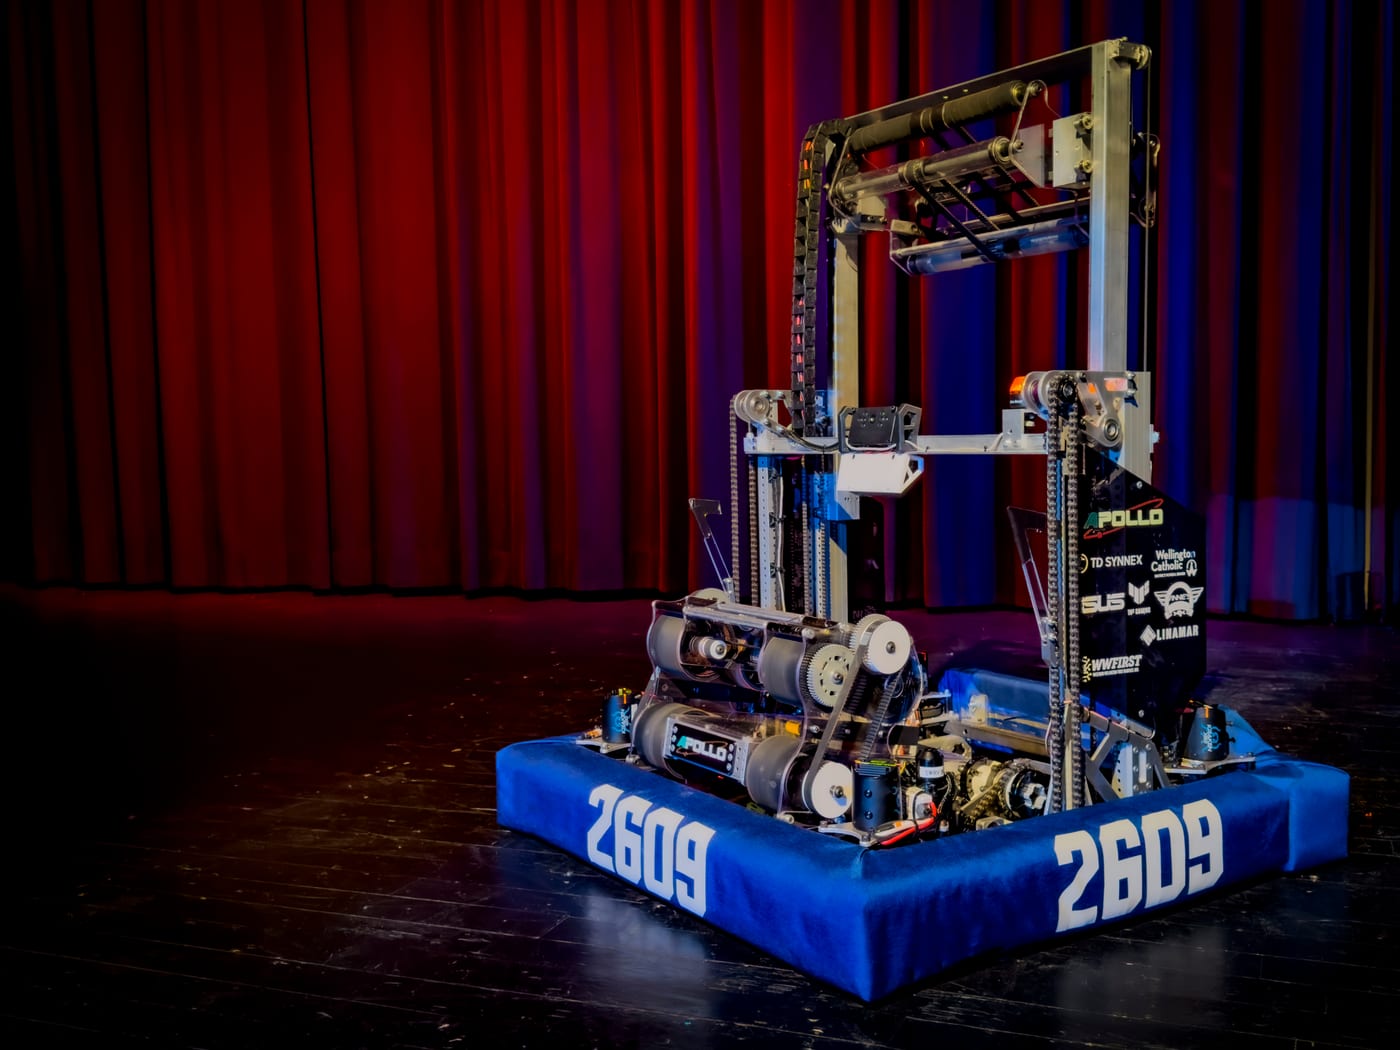
    Apollo was Team 2609's 2024 competition robot, built for CRESCENDO. A swerve drivetrain paired with a variable-angle, quadruple-flywheel shooter, driven by two Kraken motors, to score Notes from range, fed by a ground intake tucked under the bumpers. An elevator raised to score Notes in the Amp, and a chain-driven climber handled the endgame.

    • Qualified for the FIRST Championship in Houston, competed in the Milstein Division
    • Also competed at the Ontario Provincial Championship (Science Division), and the Waterloo & Durham College District Events
    Drivetrain
    Swerve
    Shooter
    Variable-angle, quadruple flywheel, two Kraken motors
    Scoring
    Elevator raises to score Notes in the Amp
    Intake
    Ground intake, mounted under the bumpers
    Climber
    Chain-driven
    Watch this Robot in Action!(opens in a new tab)Final score 108–50 in Qualification 59, ONT District University of Waterloo Event
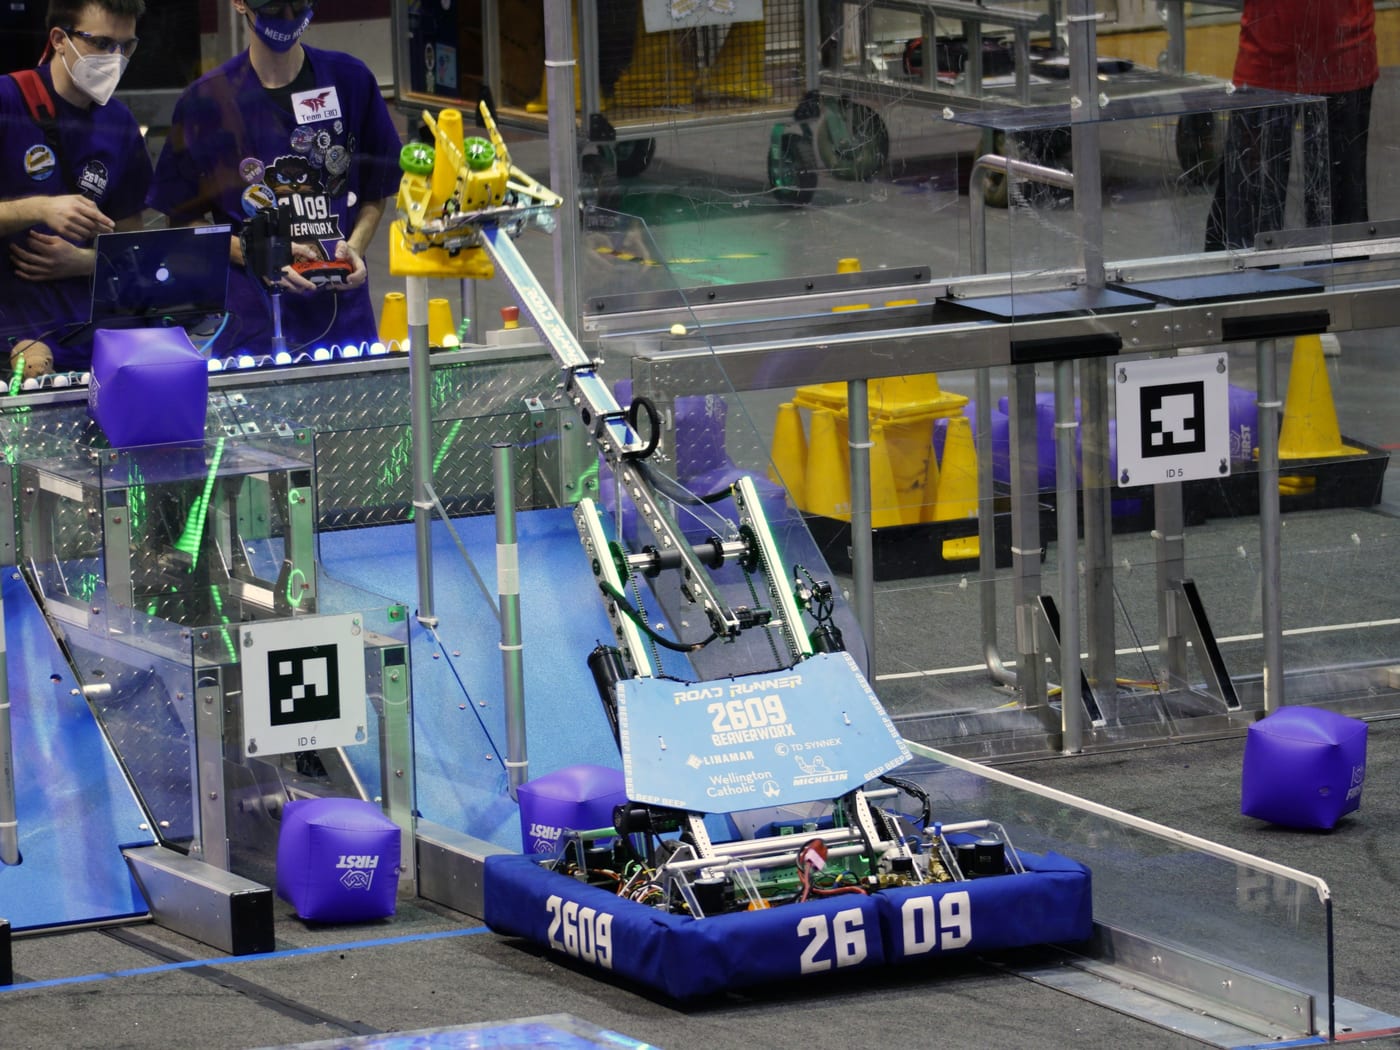
  • The Road Runner, a Team 2609 competition robotThe Road Runner
    2023CHARGED UPWorld Champion

    The Road Runner

    The Road Runner won the 2023 FIRST Robotics Competition World Championship on Einstein Field in Houston, Texas. Team 2609's alliance took the Championship after winning the Hopper Division. Its signature feature was "Beaver Boost": a custom swerve module using an electronically variable transmission, inspired by hybrid-car drivetrains, to blend two motors' output into a module that could trade off between speed and pushing power on the fly. A two-jointed arm with a pneumatic claw gripper handled cones and cubes.

    • 2023 FIRST World Championship, Houston: Einstein Field, Championship Winner
    • Hopper Division, Championship Division Winner
    • Judges' Award, Ontario Provincial Championship (Science Division)
    • Creativity Award sponsored by Rockwell Automation, McMaster & Waterloo District Events
    Drivetrain
    Custom "Beaver Boost" swerve, 3-motor ECVT modules (2× REV NEO + 1× REV NEO 550)
    Arm
    2-jointed dynamic arm, REV MAX SPLINE tubing
    End effector
    Pneumatic claw gripper, polycarbonate, photoelectric auto-grip sensor
    Vision & software
    Limelight 2+, NavX-MXP gyroscope, PID + motion-profiled control
    Watch this Robot in Action!(opens in a new tab)Final score 200–189 in Semifinal 11, FIRST World Championship, Houston
  • Bruno Bars, a Team 2609 competition robotBruno Bars
    2022RAPID REACT

    Bruno Bars

    Bruno Bars was Team 2609's 2022 competition robot, built for RAPID REACT. A tank drivetrain carried a 270°-rotating turret with a dual-flywheel shooter, four REV NEO motors, to launch cargo, fed by a ground intake. A belt-driven climber swung the robot up through the rung ladder to the traversal bar.

    • District Event Winner, ONT District North Bay Event
    • District Event Finalist, ONT District University of Waterloo Event
    • Also competed at the Ontario Provincial Championship
    Drivetrain
    Tank drive
    Turret & shooter
    270° rotating turret, dual flywheel, 4× REV NEO motors
    Intake
    Ground intake
    Climber
    Belt-driven, swings up to the traversal bar
    Watch this Robot in Action!(opens in a new tab)Final score 117–106 in Quarterfinal 4, FIRST Ontario Provincial Championship
  • Everybot, a Team 2609 competition robotEverybot
    2020INFINITE RECHARGE

    Everybot

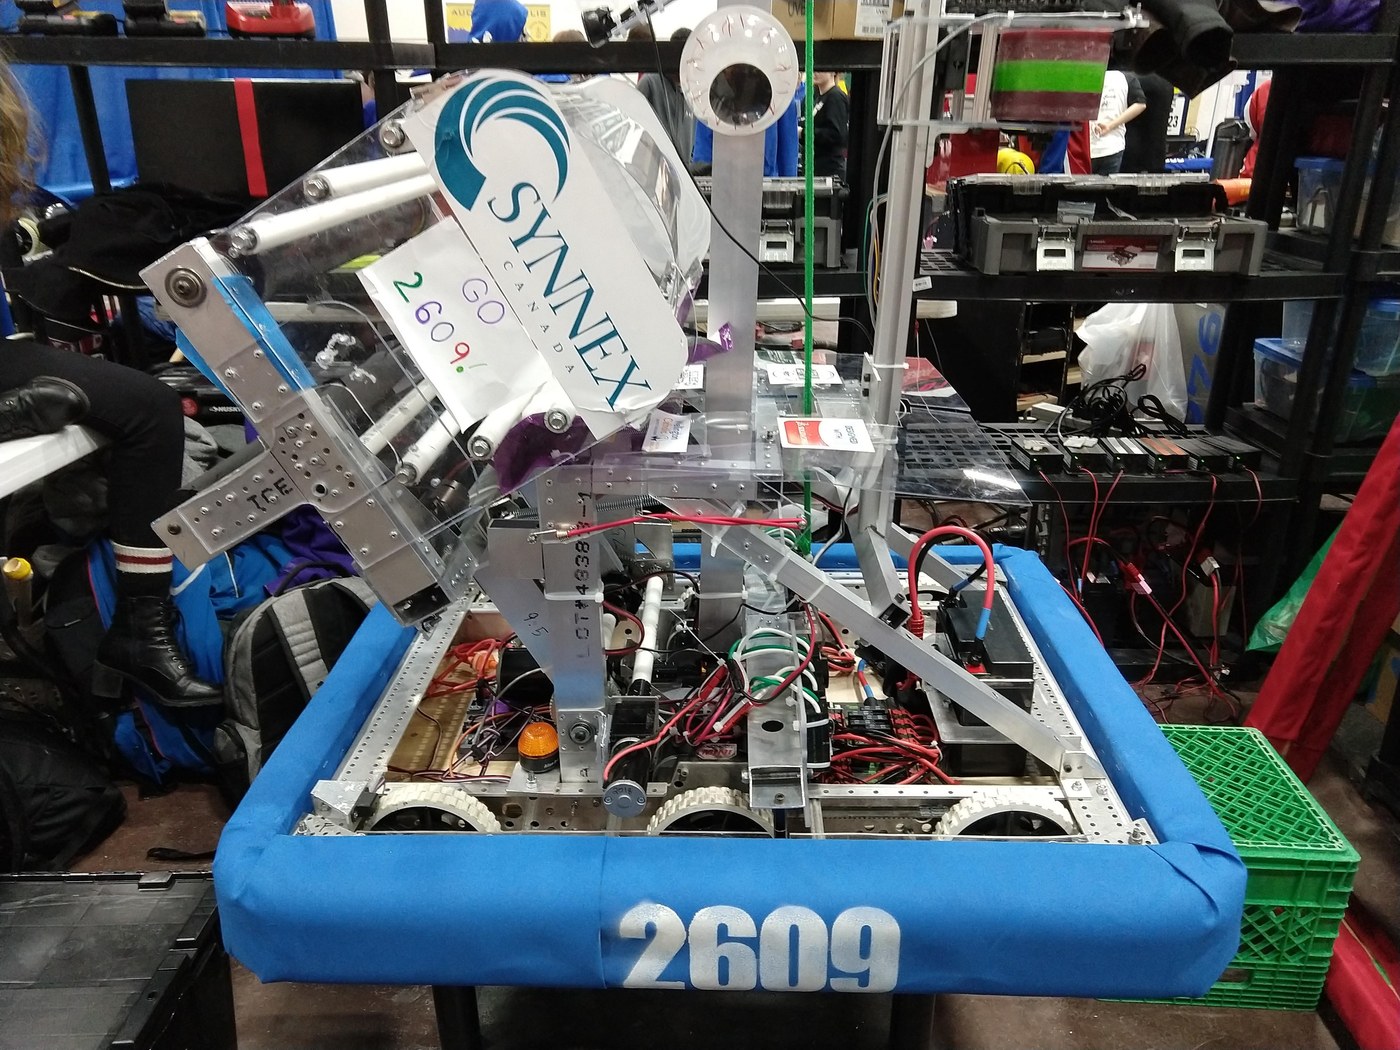
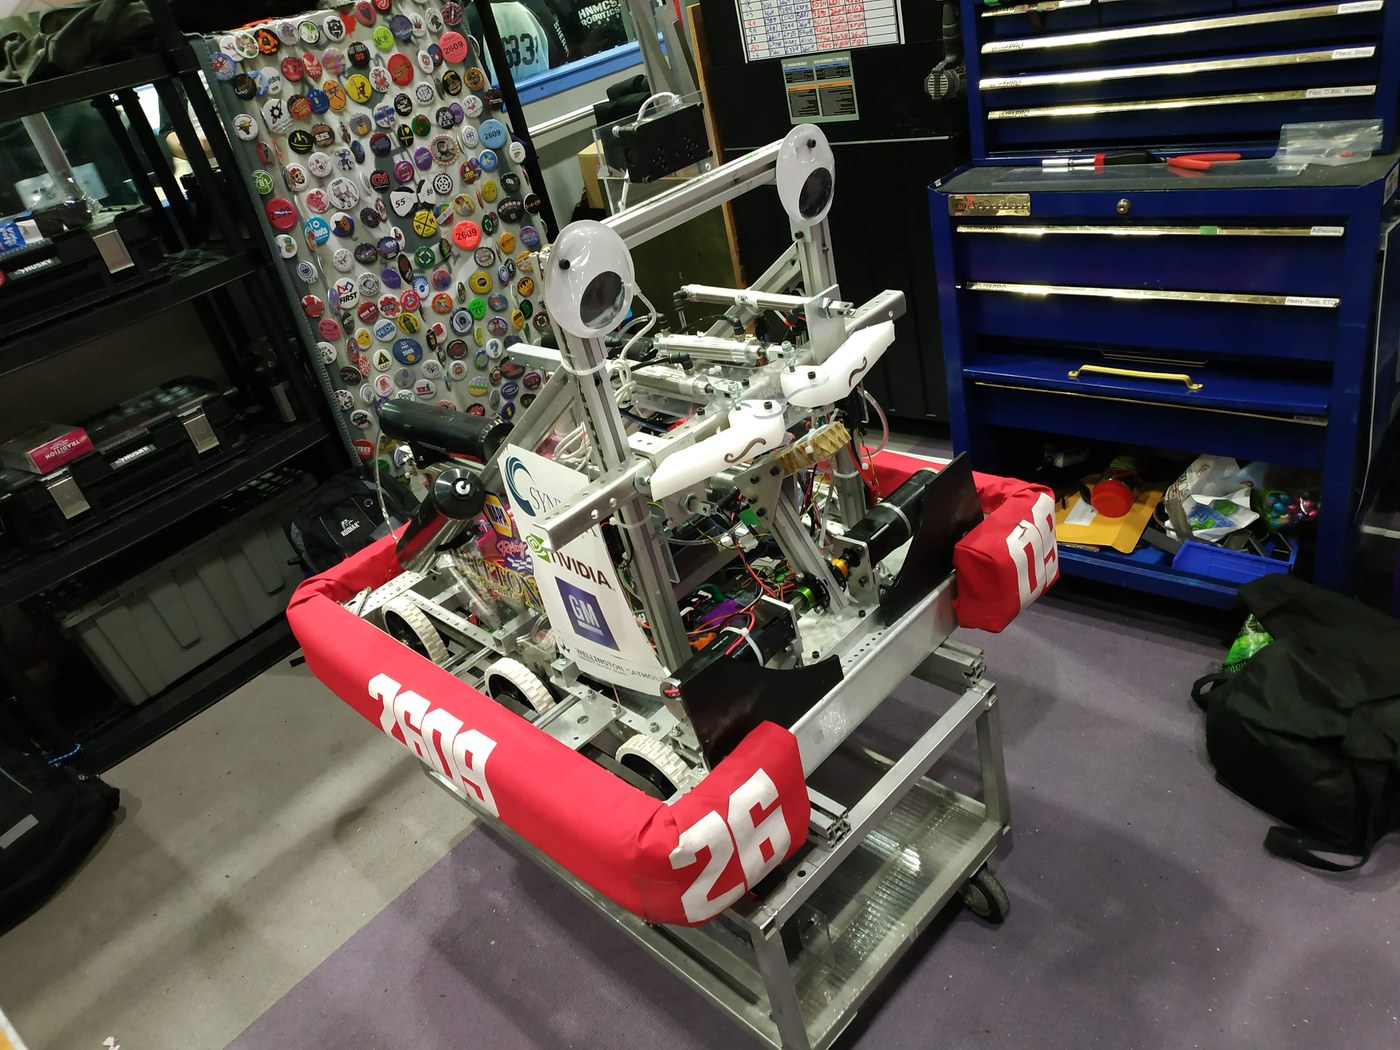
    Everybot was Team 2609's 2020 competition robot, built for INFINITE RECHARGE. Based on FIRST's own reference-design Everybot and given a googly-eyed personality, the team upgraded it with a climber to hang from the Generator Switch. A tank drivetrain carried it around the field, scoring Power Cells in the Power Port's low goal.

    • District Event Finalist, ONT District Durham College Event
    • Also competed at the ONT District Georgian College Event
    Drivetrain
    Tank drive
    Base design
    Built on FIRST's official Everybot reference design, upgraded with a climber
    Scoring
    Scored Power Cells in the Power Port's low goal
    Watch this Robot in Action!(opens in a new tab)Final score 184–236 in Final, ONT District Durham College Event
  • Hatch Back, a Team 2609 competition robotHatch Back
    2019DESTINATION: DEEP SPACE

    Hatch Back

    Hatch Back was Team 2609's 2019 competition robot, built for DESTINATION: DEEP SPACE. A tank drivetrain carried a pneumatically actuated ground intake that collected Hatch Panels and delivered them to the Cargo Ship and Rocket.

    • Competed at the STEMley Cup Championship, the ONT District Western University Western Engineering Event, and the ONT District University of Waterloo Event
    Drivetrain
    Tank drive
    Intake
    Ground pickup for Hatch Panels, pneumatically actuated
    Watch this Robot in Action!(opens in a new tab)Final score 74–54 in Qualification 35, ONT District Western University, Western Engineering Event
  • Vaultboy, a Team 2609 competition robotVaultboy
    2018POWER UP

    Vaultboy

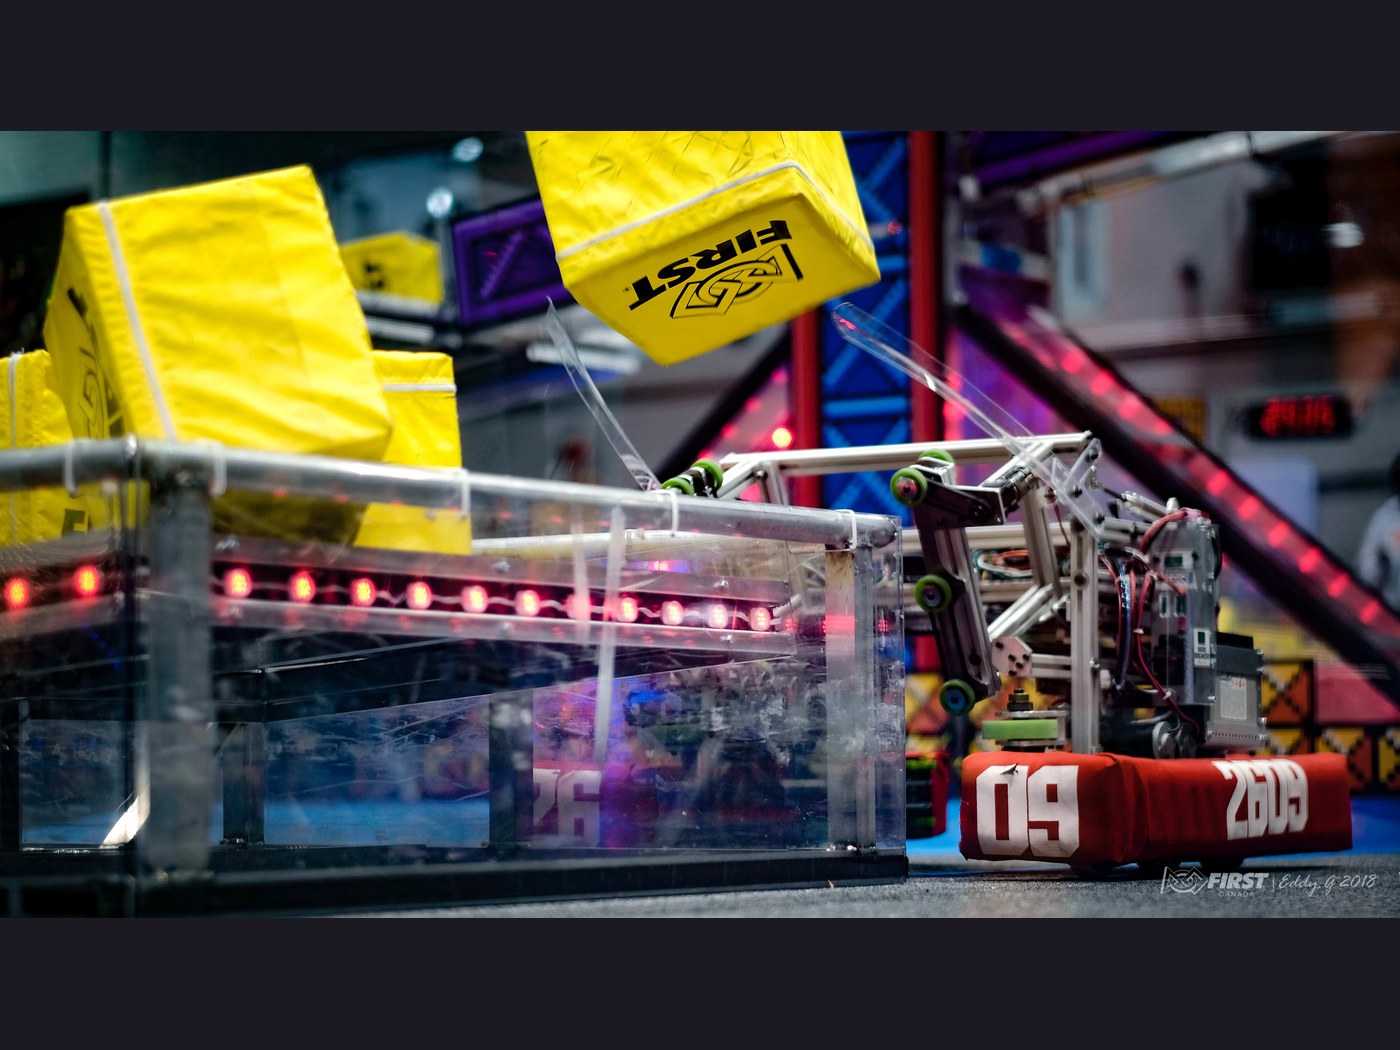
    Vaultboy was Team 2609's 2018 competition robot, built for POWER UP. A tank drivetrain carried a pass-through mechanism that could intake a Power Cube off the ground and score it in one continuous motion, feeding cubes to the Switch and the alliance's Vault for power-ups.

    • Qualified for the FIRST Championship, Detroit, competed in the Tesla Division
    • Creativity Award sponsored by Xerox, FIRST Ontario Provincial Championship (Technology Division) & ONT District McMaster University Event
    • Innovation in Control Award sponsored by Rockwell Automation, ONT District University of Waterloo Event
    • District Event Finalist and Excellence in Engineering Award sponsored by Delphi, ONT District Durham College Event
    Drivetrain
    Tank drive
    Intake & scoring
    Pass-through design, ground pickup that intakes and scores Power Cubes in one motion
    Scoring
    Delivered cubes to the Switch and the alliance Vault
    Watch this Robot in Action!(opens in a new tab)Final score 519–123 in Qualification 25, ONT District University of Waterloo Event
  • Norbu, a Team 2609 competition robotNorbu
    2017STEAMWORKS

    Norbu

    Norbu was Team 2609's 2017 competition robot, built for STEAMWORKS. A tank drivetrain carried a ground intake for Fuel, scoring into the Boiler's low goal, alongside a separate ground pickup for Gears delivered to the airship's Pilots. A winch-driven rope climber let Norbu align itself to the rope and pull itself up at the end of the match, with an onboard camera helping the driver see the robot from behind the airship.

    • Qualified for the FIRST Championship, St. Louis, competed in the Curie Division
    • District Event Finalist and Excellence in Engineering Award sponsored by Delphi, ONT District Ryerson University Event
    • Innovation in Control Award sponsored by Rockwell Automation, ONT District Durham College Event
    Drivetrain
    Tank drive, driver-assist camera to see the robot from behind the airship
    Fuel intake
    Ground pickup, scored in the Boiler's low goal
    Gear intake
    Ground pickup, delivered Gears to the airship Pilots
    Climber
    Winch-driven rope climb, aligns to the rope and pulls itself up
    Watch this Robot in Action!(opens in a new tab)Final score 498–465 in Quarterfinal 3, FIRST Ontario Provincial Championship
  • PR Limbobot, a Team 2609 competition robotPR Limbobot
    2016STRONGHOLD

    PR Limbobot

    PR Limbobot was Team 2609's 2016 competition robot, built for STRONGHOLD, with a low enough profile to clear the Low Bar defense. A ground intake collected Boulders to score in the tower, and PR Limbobot could cross multiple Outer Works defenses to help breach it.

    • Regional Finalist and Innovation in Control Award sponsored by Rockwell Automation, Greater Toronto Central Regional
    • Also competed at the STEMley Cup Championship and the Windsor Essex Great Lakes Regional
    Drivetrain
    Tank drive, low profile to clear the Low Bar defense
    Intake
    Ground pickup for Boulders, scored in the tower
    Defense crossing
    Could cross multiple Outer Works defenses
    Watch this Robot in Action!(opens in a new tab)Final score 162–82 in Quarterfinal 2, Windsor Essex Great Lakes Regional
  • Bendgate, a Team 2609 competition robotBendgate
    2015RECYCLE RUSH

    Bendgate

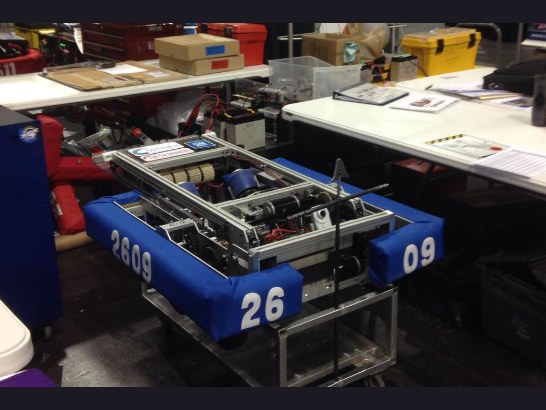
    Bendgate was Team 2609's 2015 competition robot, built for RECYCLE RUSH. A tank drivetrain carried an elevator that picked up and stacked Totes.

    • Qualified for the FIRST Championship, St. Louis, competed in the Hopper Division
    • Also competed at the North Bay Regional and the Greater Toronto Central Regional
    Drivetrain
    Tank drive
    Scoring
    Elevator picks up and stacks Totes
    Watch this Robot in Action!(opens in a new tab)Final score 167–57 in Qualification 42, Greater Toronto Central Regional
  • Polar Vortex, a Team 2609 competition robotPolar Vortex
    2014AERIAL ASSIST

    Polar Vortex

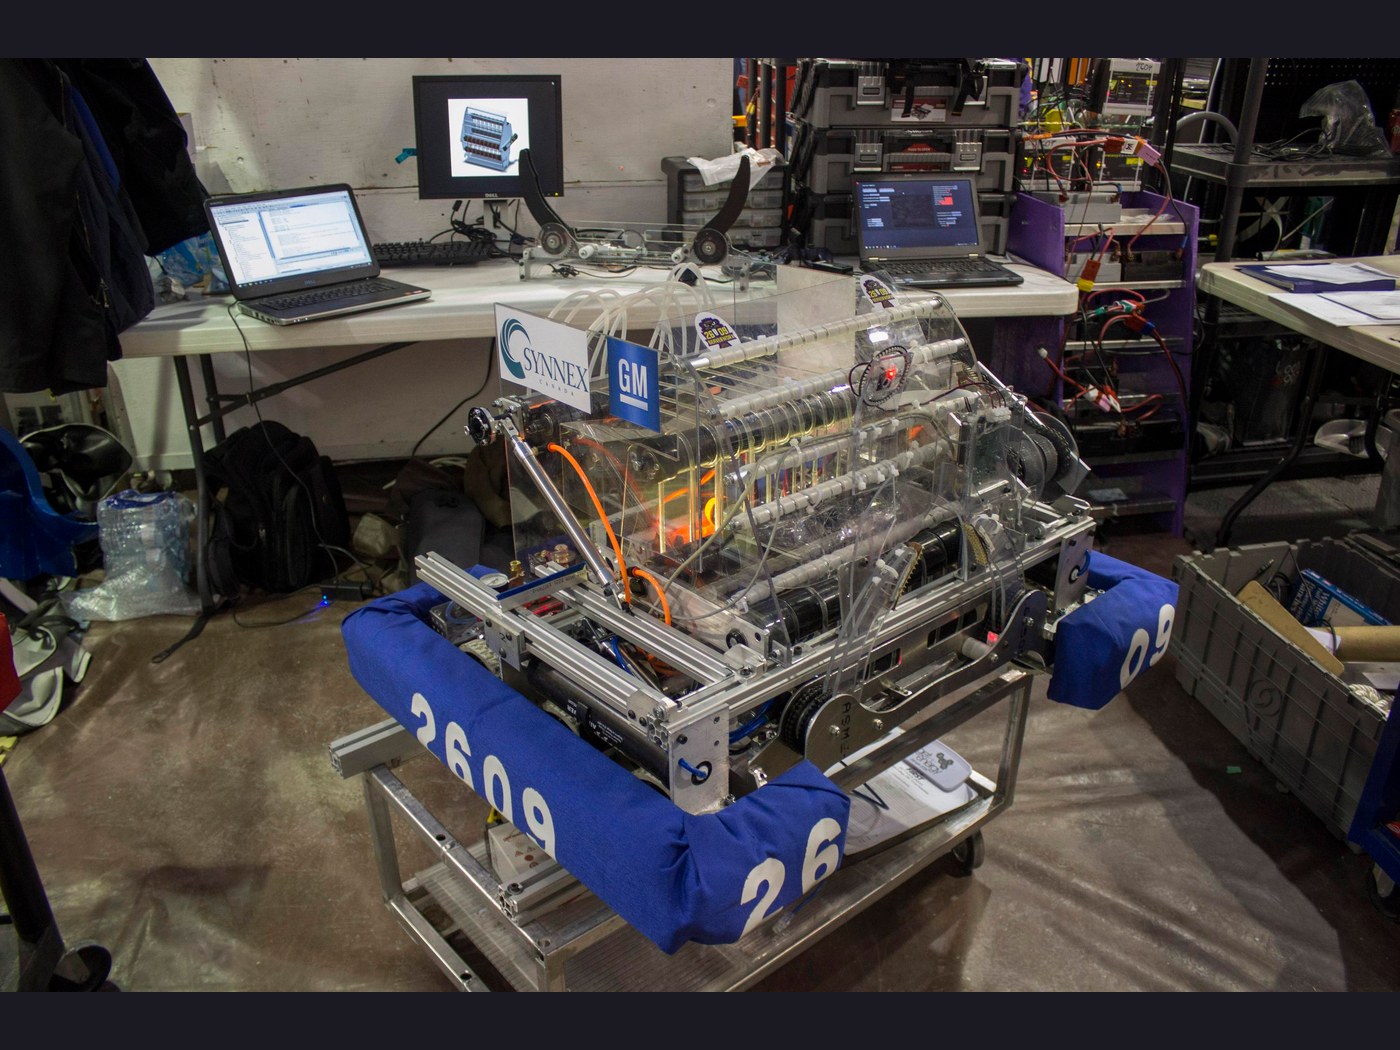
    Polar Vortex was Team 2609's 2014 competition robot, built for AERIAL ASSIST. A 6-wheel Kiwi drivetrain gave it holonomic motion, carrying a ground intake that opened up to catch passed balls and a spring-loaded catapult to launch them downfield for goals and assists.

    • Competed at the North Bay Regional, the Waterloo Regional, and the Greater Toronto East Regional
    Drivetrain
    6-wheel Kiwi drive, holonomic motion
    Intake
    Ground pickup, opens up to catch passed balls
    Launcher
    Spring-loaded catapult
    Watch this Robot in Action!(opens in a new tab)Final score 286–22 in Qualification 14, North Bay Regional

More seasons coming soon